|
I am a first-year M.S. student in the Department of Automation at Tsinghua University, advised by Prof. Jiwen Lu. In 2025, I obtained my B.Eng. in the Department of Automation from Beihang University. I work on robotics. My current research focuses on:
|
|
|
*Equal contribution, †Project leader. |
|
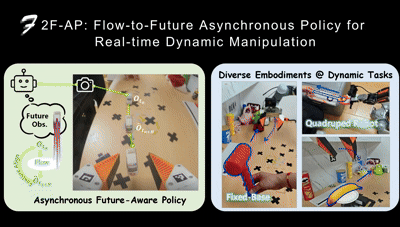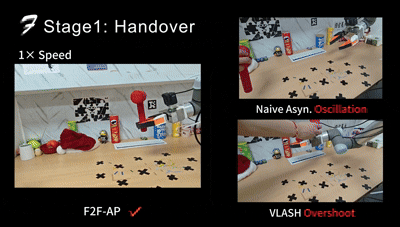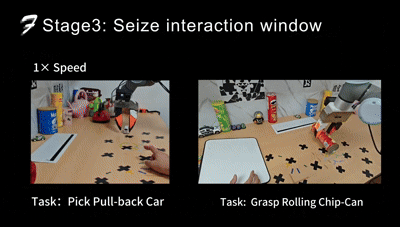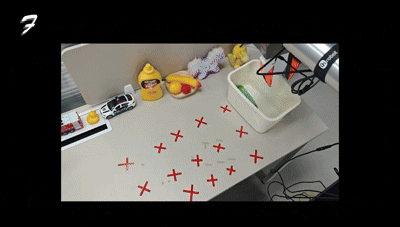
Haoyu Wei, Xiuwei Xu†, Ziyang Cheng, Hang Yin, Angyuan Ma, Bingyao Yu, Jie Zhou, Jiwen Lu arXiv, 2026 [arXiv] [Project Page] To address observation lag in asynchronous inference, we use optical-flow prediction and contrastive learning to predict future observations in the feature space, align actions with their true execution timeline, and improve success rates on highly dynamic tasks. |
|
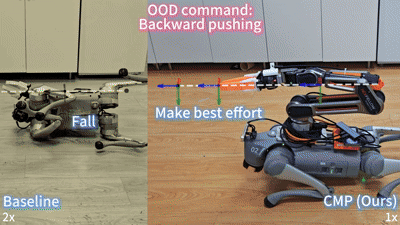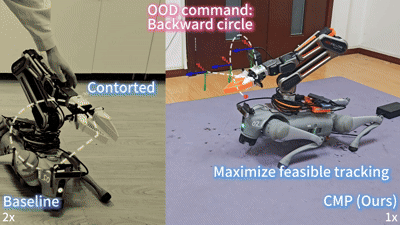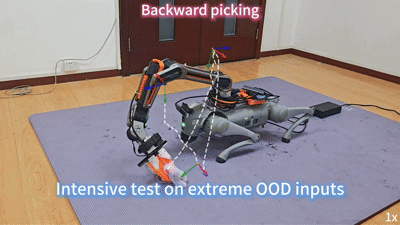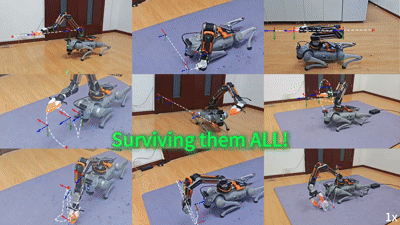
Ziyang Cheng, Haoyu Wei, Hang Yin, Xiuwei Xu, Bingyao Yu, Jie Zhou, Jiwen Lu arXiv, 2026 [arXiv] [Project Page] Competence Manifold Projection (CMP) aims to solve the problem that learning holistic whole-body control policies for tracking global end-effector poses remains fragile against Out-of-Distribution (OOD) inputs induced by sensor noise or infeasible user commands. |
|
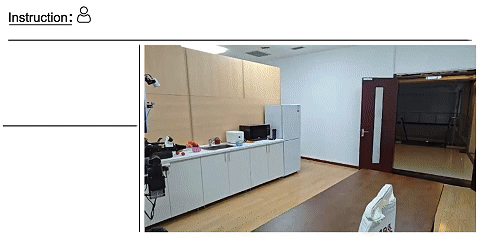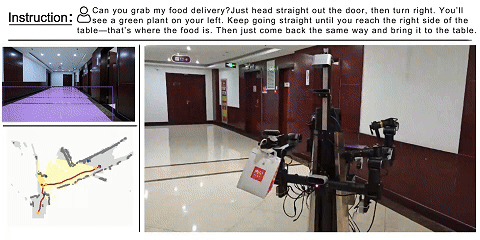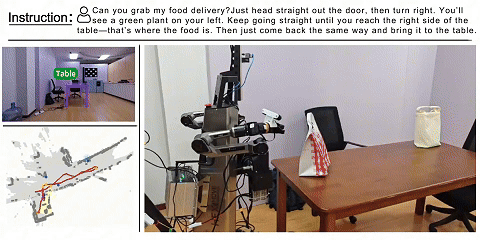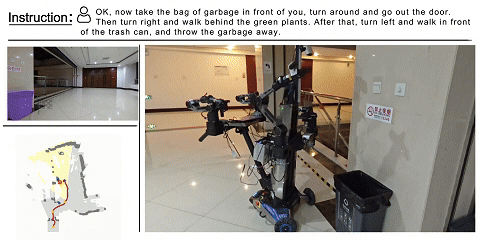
Hang Yin*, Haoyu Wei*, Xiuwei Xu, Wenxuan Guo, Jie Zhou, Jiwen Lu arXiv, 2025 [arXiv] [Project Page] We propose a general framework for mobile manipulation, which can be divided into docking point selection and fixed-base manipulation. We model the docking point selection stage as an optimization process, to let the agent move and touch target keypoint under several constraints. |
|
© Haoyu Wei | Last updated: October 28, 2026 |